VIDA Projects

We prototype, test, and validate
what the track demands next.

156
Prototype Hours Logged
220
Test Sessions Analyzed
590
Iterations Shipped

Engineering What’s Next

A short preview of what we are validating now,
before it ships into VIDA Walk.

Protoype

Predictive Lap

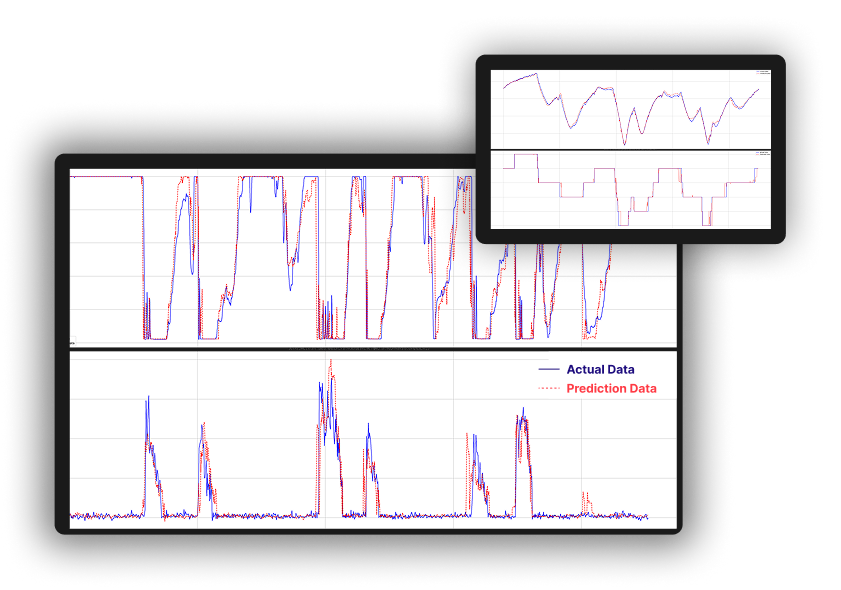
A prototype that estimates achievable lap potential and highlights the segments that matter most. It is designed to help prioritize the next adjustment with discipline, rather than chasing noise in the data.

Validation focuses on repeatability across different sessions and conditions, so the guidance stays stable and actionable.

Real-time data analysis graphs for vehicle performance optimization.
Protoype

Owen

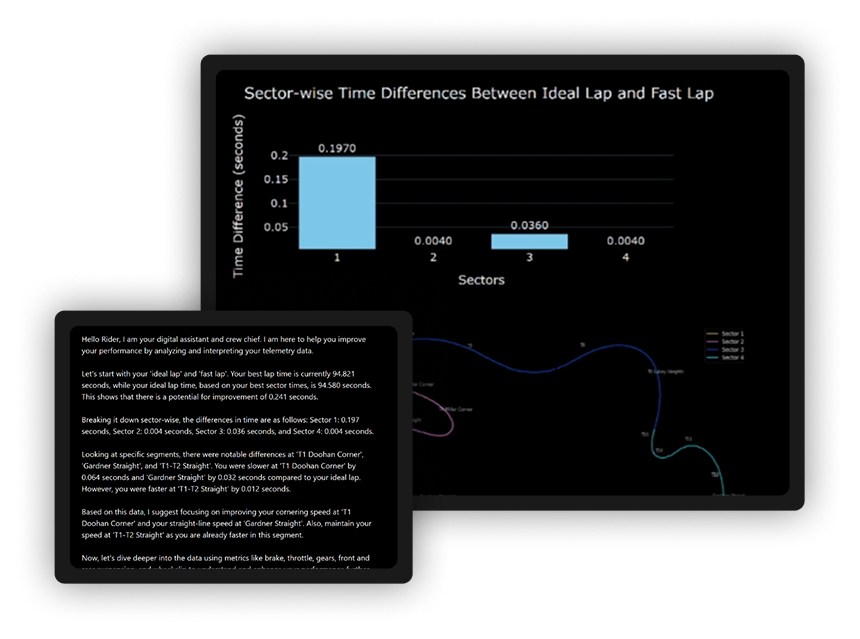
A virtual crew chief built to turn post-session data into a trackside debrief that is fast, structured, and decision-focused. It compares runs, filters the noise, and surfaces the differences that actually move the lap, so the next checks are obvious.

Owen is developed iteratively using engineering literature and real track feedback, expanding only when outputs stay consistent in use.

High-performance racing car on the track with advanced engineering.
Concept

Smartphone Based IMU Metrology

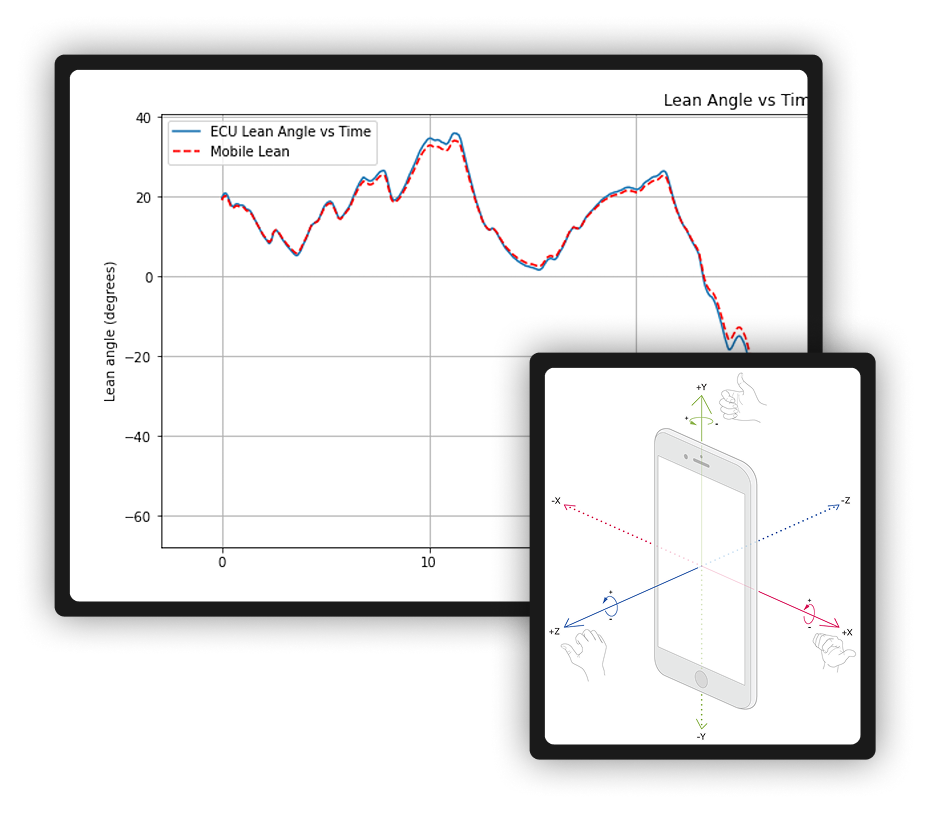
This project explores how a smartphone can become a dependable motion measurement tool for vehicle dynamics, without requiring dedicated data acquisition hardware.

The work focuses on calibration, consistency, and validation so outputs remain stable across real-world mounting and operating conditions. If results meet our quality thresholds, it opens professional-grade insight to a much wider community. ”

Advanced vehicle lean angle monitoring system for automotive projects.

Join VIDA Today

Start free. Try every feature for 30 days.
Refined through real track feedback.

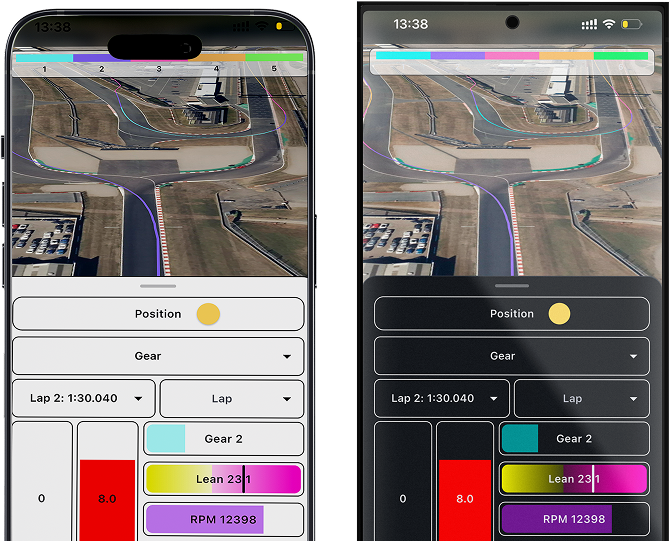
Advanced racing telemetry app for track performance analysis.